Move Into Contact
| Description |
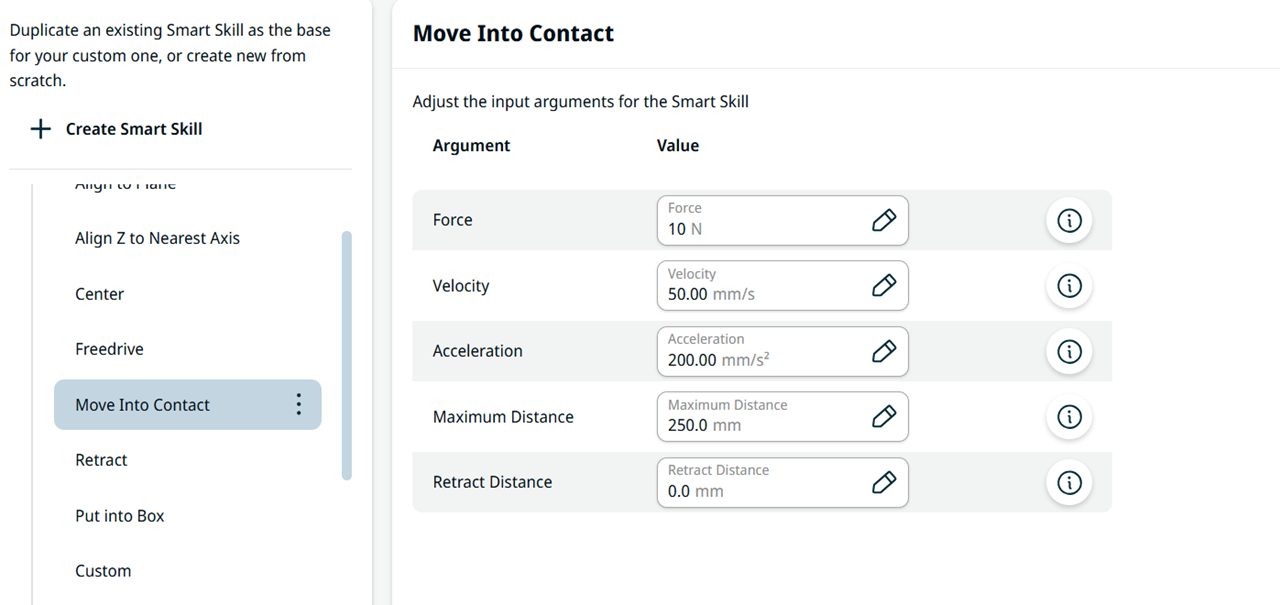
The Move Into Contact Smart Skill moves the robot in the TCP +Z direction until it reaches a contact point. The robot then retracts by the Retract Distance. The default retract distance is 0 mm.
|
|
Function |
You can configure Force, Velocity, Acceleration, Maximum Distance, and Retract Distance. The Smart Skill zeroes the force/torque sensor at the start and moves along TCP +Z.
|