Technical Specifications Robot Arm (g-Series)

Description

This section contains the technical information for the robot arm.


General Specifications

 
  UR10g-1750 UR17g-1300 UR18g-950
Maximum payload

10 kg / 22 lbs. For maximum payload, see Maximum Payload g-Series.

17.5 kg / 38.58 lbs. For maximum payload, see Maximum Payload g-Series.

18 kg / 39.7 lbs

Reach

1750 mm / 68.9 in

1300 mm / 51.18 in

950 mm / 37.4 in

Degrees of freedom 6 rotating joints
Joint architecture 2-1-3
Power consumption (average)

Maximum power consumption: 615 W

Average power consumption: 350 W

Maximum power consumption: 550 W

Average power consumption: 350 W

Maximum power consumption: 570 W

Average power consumption: 350 W

Control loop frequency 500 Hz
Base flange connectors Harting Plug
Safety functions

23 configurable safety functions. PLd Category 3 in accordance with: EN ISO 13849-1.

In safety compliance with

TÜV Rheinland EN ISO 13849-1 (PLd Category 3),

TÜV Rheinland EN ISO 10218-1

and UL 1740

Directives and regulatory compliance with

CE Declaration of Incorporation

KC Mark

RoHS


Physical Specifications

 
  UR10g-1750 UR17g-1300 UR18g-950
Footprint Ø204 mm / Ø8.03 in Ø204 mm / Ø8.03 in Ø204 mm / Ø8.03 in
Base size Size 4 g-Series
Materials Aluminium, plastic, steel
Tool flange ISO 9409-1-50-4-M6
Weight including cable 47.3 kg / 104.3 lbs 43.4 kg / 95.7 lbs 42 kg / 92.6 lbs

Movement

 
  UR10g-1750 UR17g-1300 UR18g-950
Maximum TCP speed 5 m/s 5 m/s 4 m/s
Pose repeatability per ISO 9283 ± 0.08 mm ± 0.05 mm ± 0.05 mm
Working range (all joints) ± 360° for all joints
Axis movement — maximum speed
Base ± 180°/s ± 180°/s ± 180°/s
Shoulder ± 180°/s ± 180°/s ± 180°/s
Elbow ± 240°/s ± 240°/s ± 240°/s
Wrist 1 ± 300°/s ± 300°/s ± 300°/s
Wrist 2 ± 300°/s ± 300°/s ± 300°/s
Wrist 3 ± 300°/s ± 300°/s ± 300°/s


Environment

 
  UR10g-1750 UR17g-1300 UR18g-950
Operating temperature (ambient)

0–50 °C / 32–122 °F

Reduced performance from 35 °C and up.

Humidity ≤ 90% RH (non-condensing)
Noise level < 55 dB(A) < 55 dB(A) < 55 dB(A)
Pollution degree

2

Protection

 
  UR10g-1750 UR17g-1300 UR18g-950
IP classification

IP65

Force Torque

 
Force-torque sensing at tool flange Force, x-y-z Torque, x-y-z
Range ± 150.0 N ± 10.0 Nm
Precision ± 7.5 N ± 0.2 Nm
Accuracy ± 8.3 N ± 0.5 Nm


Electrical interface

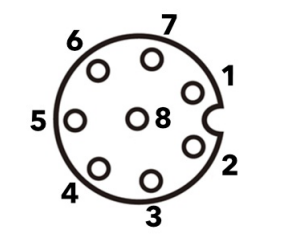
M8 I/O 8-Pin Tool Connector

Pin # Signal Description
1 T0_AI1 / RS485- Analog Input 1 or RS485-
2 T0_AI0 / RS485+ Analog Input 0 or RS485+
3 T0_DO0/PWR Digital Output 0 or 0V/12V/24V
4 T0_DO1/GND Digital Output 1 or Ground
5 T0_V Power 0V/12V/24V
6 T0_CI0 Digital Input 0 / Safety Input
7 T0_CI1 Digital Input 1 / Safety Input
8 GND Ground

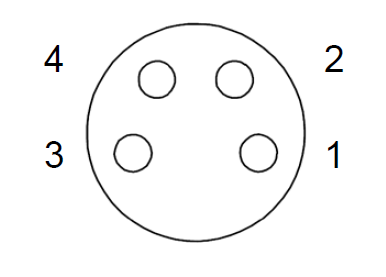
M8 Power 4-Pin Tool Connector

Pin # Signal Description
1 - +24/+48 V power
2 - +24/+48 V power
3 - Ground
4 - Ground

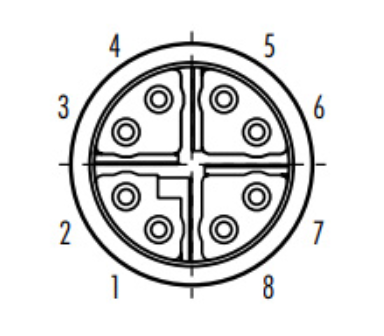
M12 Ethernet Tool Connector

Pin # Signal Description
1 - D1+
2 - D1-
3 - D2+
4 - D2-
5 - D3+
6 - D3-
7 - D4+
8 - D4-
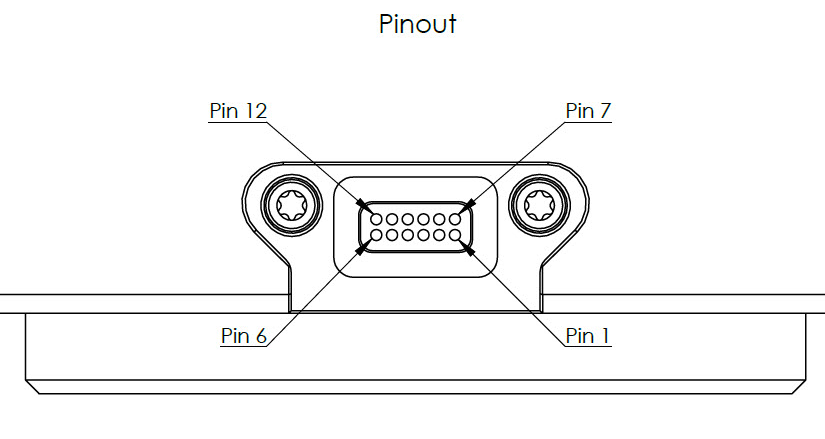
Smart Panel Interface

Pin

Signal Description

1

T1_CI1

Safety Digital Input 1

2

GND

Ground

3

T1_DO0

Digital Output 0

4

T1_DO1

Digital Output 1

5

T1_DO2

Digital Output 2

6

T1_DO3

Digital Output 3

7

T1_CONNECTED

Presence Detection

8

5 V

5 V output voltage

9

T1_CI0

Safety Digital Input 0

10

T1_DI0

Digital Input 0

11

T1_DI1

Digital Input 1

12

T1_DI2

Digital Input 2