Dimensioning the Stand

Description

The structure (stand) on which the robot arm is mounted is a crucial part of the robot installation. The stand must be sturdy and free of any vibrations from external sources.


The magnitude of the loads depends on robot model, program, and multiple other factors.

Dimensioning of the stand shall account for the loads that the robot arm generates during normal uninterrupted operation and during category 0, 1, and 2 stopping motion.


  • Potential tip-over hazards.

  • The robot arm's operational loads can cause movable platforms, such as tables or mobile robots, to tip over, resulting in possible accidents.

  • Prioritize safety by implementing adequate measures to prevent the tipping of movable platforms at all times.

  • If the robot is mounted on an external axis, the accelerations of this axis must not be too high.

    You can let the robot software compensate for the acceleration of external axes by using the script command:
    set_base_acceleration()

  • High accelerations can cause the robot to make safety stops.

Dimensioning the Stand

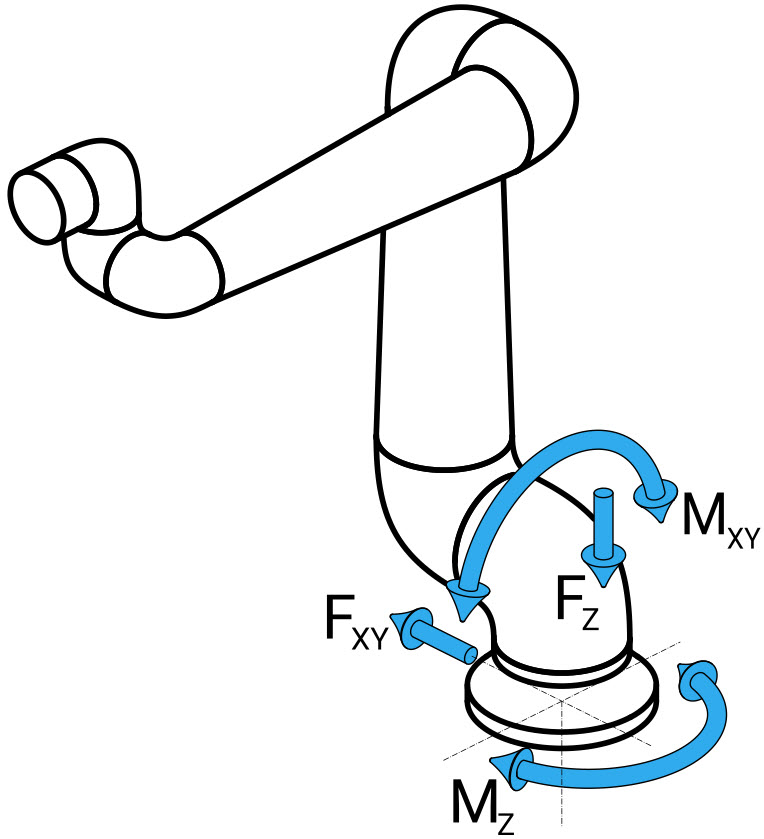
Each robot joint produces a torque that moves and stops the robot arm. During normal uninterrupted operation and during stopping motion, the joint torques are transferred to the robot stand as:

  • Mz: Torque around the base z-axis.

  • Fz: Force along the base z-axis.

  • Mxy: Tilting torque in any direction in the base xy plane.

  • Fxy: Force in any direction in the base xy plane.

Force and moment at the base flange definition.


During stopping motion, the joints are allowed to exceed the maximum nominal operating torque. The load during stopping motion is independent of the stop category type.

The values stated in the following tables are maximum nominal loads in worst-case movements multiplied by a safety factor of 2.5. The actual loads will not exceed these values.

Robot Model

Mz

Fz

Mxy

Fxy

UR10g-1750

1310 Nm

2240 N

1690 Nm

1380 N

UR17g-1300

1310 Nm

2430 N

1730 Nm

1720 N

UR18g-950

1310 Nm

2600 N

1740 Nm

2000 N

Maximum joint torques during category 0, 1, and 2 stops.


Robot Model

Mz

Fz

Mxy

Fxy

UR10g-1750

1090 Nm

1870 N

1170 Nm

1100 N

UR17g-1300

1090 Nm

1860 N

1310 Nm

1490 N

UR18g-950

1090 Nm

2020 N

1500 Nm

1630 N

Maximum joint torques during normal operation.


The normal operating loads can generally be reduced by lowering the acceleration limits of the joints. Actual operating loads are dependent on the application and robot program. You can use URSim to evaluate the expected loads in your specific application.


Safety margins

You can incorporate added safety margins, factoring in the following design considerations:


  • Static stiffness: A stand that is not sufficiently stiff will deflect during robot motion, resulting in the robot arm not hitting the intended waypoint or path. Lack of static stiffness can also result in a poor Freedrive teaching experience or robot stops.

  • Dynamic stiffness: If the frequency of the stand matches the movement frequency of the robot arm, the entire system can resonate, creating the impression that the robot arm is vibrating. Lack of dynamic stiffness can also result in robot stops. The stand should have a minimum resonance frequency of 45 Hz.

  • Fatigue: The stand shall be dimensioned to match the expected operating lifetime and load cycles of the complete system.

Fixed and Movable Installation

Whether the robot arm is fixed (mounted to a stand, wall, or floor) or in a movable installation (linear axis, push cart, or mobile robot base), it must be installed securely to ensure stability through all motions.

The design of the mounting must ensure stability during movements of:

  • the robot arm

  • the robot base

  • both robot arm and robot base

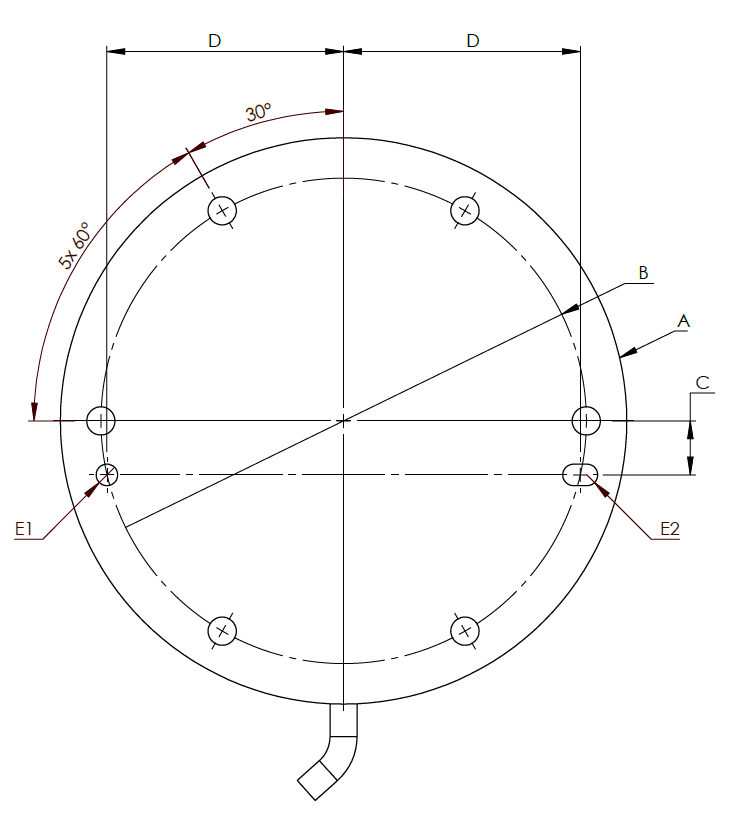
Dimensioning a base plate for mounting the robot

Bottom view of g-Series robot base

  UR10g-1750 UR17g-1300 UR18g-950

A

Outside diameter

204 mm 204 mm 204 mm

B

Pitch circle diameter

180 mm 180 mm 180 mm

C

Dowel hole distance from center

20 mm 20 mm 20 mm

D

Dowel hole distance from center

87.75 mm 87.75 mm 87.75 mm

E1

Dowel hole diameter

8 FG8 8 FG8 8 FG8

E2

Dowel hole diameter

8 FG8 x 13 8 FG8 x 13 8 FG8 x 13