Lifting and Mounting g-Series

Description

This section describes how to safely lift and handle the robot arm.

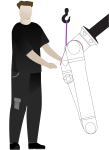
Proper lifting and mounting of the robot arm are essential for safe handling and to prevent equipment damage and personal injury. Follow the specified procedures when using lifting equipment, including a round sling, to maintain stability and control throughout the operation.

The round sling is provided by UR with g-Series robots. Use it for lifting and handling the robot arm during transport, unpacking, and mounting.


Using a damaged round sling can result in injury.

  • Carefully examine the sling visually before each use.

  • Do not use the sling if it is cracked, ripped, or the stitching is loose.

  • Do not use the sling if there are signs of heat damage.

Failure to secure the robot arm to a sturdy surface can lead to injury caused by the robot falling.

  • Ensure the robot arm is secured to a sturdy surface.

Incorrect assembly of components and/or wiring can lead to injury.

  • Personal protective gear (footwear, eyewear, gloves) can be required.

Installing or maintaining equipment connected to a power source can result in injury or death from electric shock.

  • Disconnect equipment from the power source before conducting installation or maintenance tasks.

Failure to use an appropriate lifting device for the weight of the robot can lead to injury and property damage.

Specific regulations for inspecting lifting equipment and for assembly lifting may apply in your region.

  • Observe local regulations for inspection of lifting equipment, including inspection frequency.

  • Follow local regulations and guidelines for lifting.

Round sling specifications

The round sling conforms to the following standards:

  • EN 1492-1 :2000+A1 :2008 Textile slings - Safety - Flat woven webbing slings, made of man-made fibers, for general purpose use.

  • EN 1492-2 :2000+A1 :2008 Textile slings - Safety - Round slings, made of man-made fibers, for general purpose use.

Item Color Material WLL factor

Round sling
(1T x 1 m/2 m)

Violet
(according to EN 1492-2)

Polyester

1.0 (1000 kg)


Straight Lift

0.8 (800 kg)


Choke Hitch


How to lift and mount your robot
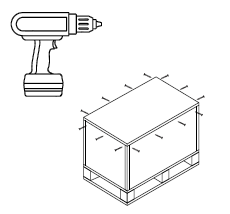
  1. Transport the robot to the site using a forklift.

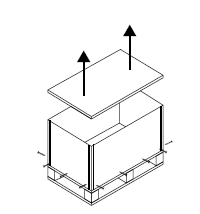
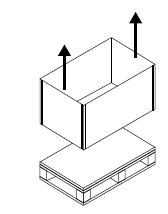
  2. Open the box as illustrated.

    Remove the upper row of screws Remove the lid and bottom screws Remove side walls
  3.  

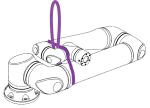
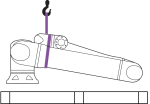
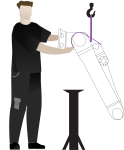
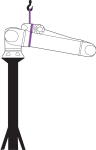
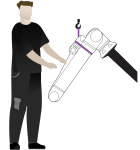
  4. Securely strap the robot arm with the lifting sling. Lift the robot arm out of the box. Support the robot arm as you rotate and hang it.

    Attach the sling Use lifting equipment Support the robot arm


  5. Mount the robot arm and secure it with six bolts.

  6. Tighten the bolts and apply torque as specified in the following table.

    Robot Bolts Torque Pins

    UR10g-1750

    UR17g-1300

    UR18g-950

    6x M10 (8.8) 45 Nm Ø8 h6, Ø8x13 mm slot
    Bolt specification
  7. Remove the sling.

Tilted mounting

The robot arm can be mounted on a tilt from -180° to 180°. The most common positions are illustrated below.

0° angle mounting Mounted at 45° Mounted at 135°


How to mount in tilted position

To mount the robot arm at a tilt, follow these steps:


  1. Secure the robot arm on a 0° stand.

  2. Follow the first boot sequence and adjust the robot base to the position that matches your desired tilt.

  3. Power down the robot.

  4. Unplug all electrical connections.

  5. Use the round sling to lift the arm into position.

  6. Mount the robot arm. Tighten the screws and apply torque as specified in the Bolt specification table.

  7. Remove the sling.