|
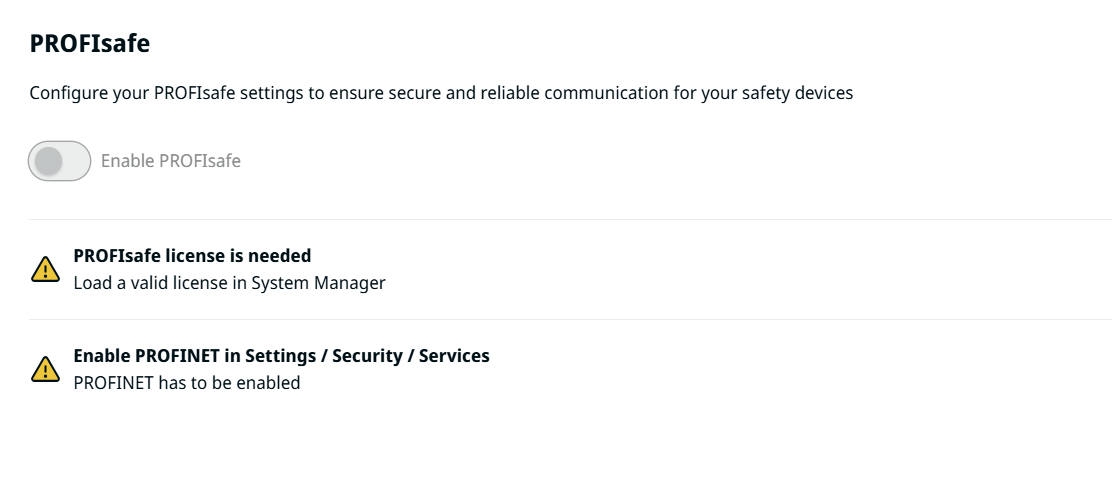
The PROFIsafe network protocol (implemented as version 2.6.1) enables the robot to communicate with a safety PLC according to ISO 13849, Cat 3 PLd requirements.
The robot transmits safety-related information to a safety PLC and receives safety-related information from it.
Safety-related communications can be state messages or can trigger a safety function (e.g. reduced settings, stop). Stop commands are described according to IEC 60204-1, where the emergency stop is a Category 1 stop and the safeguard stop is a Category 2 stop.
The PROFIsafe interface provides a safe, network-based alternative to connecting wires to the safety IO pins of the robot control box.
Using the PROFIsafe interface maintains the UR robot’s functional safety specifications (PL, category, and PFH). For details, see the “Safety Functions Table” section in the UR manual. For example, the “safeguard stop” is PLd Category 3 with a PFH value less than 1.8E-07 (1.8 x 10⁻⁷).
|