Securing the Robot Arm

Description

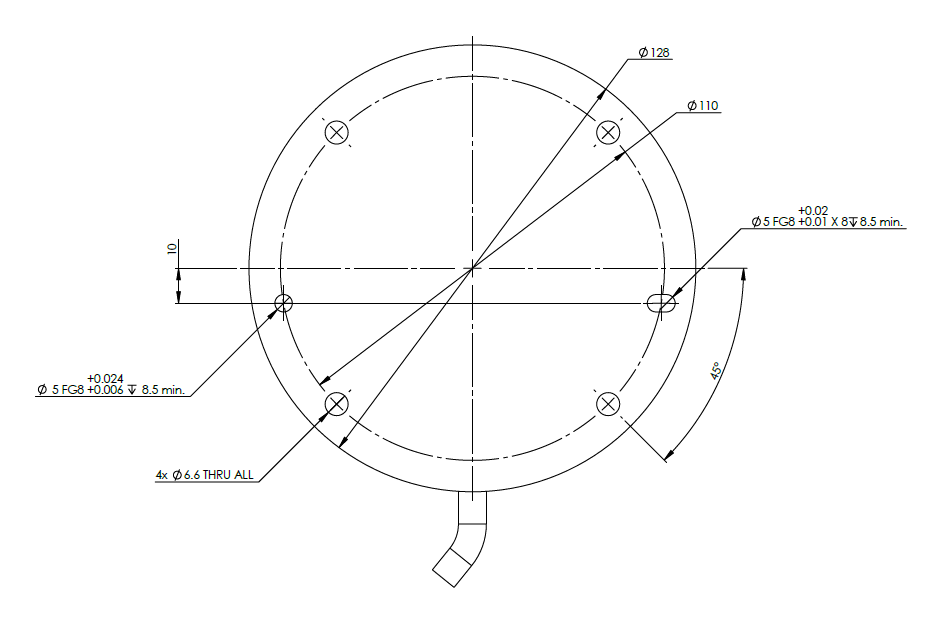
1.1:  Bottom view of Robot base

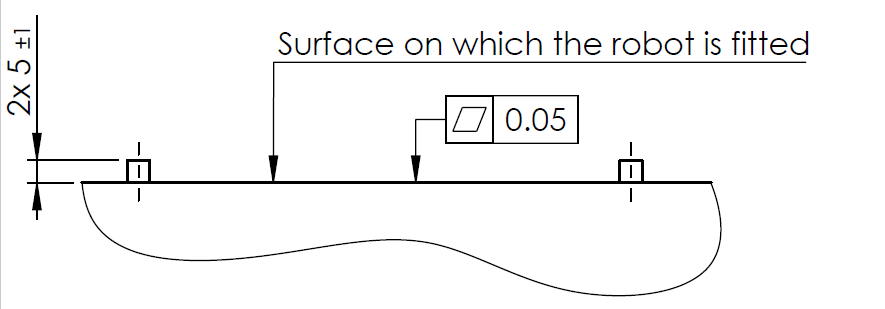
1.2:  Mounting plate for Robot base


To power down the robot arm

Unexpected startup and/or movement can lead to injury.

  • Power down the robot arm to prevent unexpected startup during mounting and dismounting.

  1. On the left side of the footer, tap the Robot State icon to turn off the robot arm.

    The icon color changes from green to white.

  2. Press the power button on the Teach Pendant to turn off the Control Box.

  3. If a Shutdown dialog box appears, tap Power Off.

You can now:

  • Unplug the mains cable/power cord from the wall socket.

  • Wait 30 seconds for the robot to discharge any stored energy.


To secure the robot arm
  1. Place the robot arm on the surface on which it is to be mounted. The surface must be even and clean.

  2. Tighten the four 8.8 strength, M6 bolts to a torque of 9 Nm.
    (Torque values have been updated SW 5.18. Earlier printed version will show different values)

  3. If accurate re-mounting of the robot is required, use the Ø5 mm. hole and Ø5x8 mm. slot with corresponding ISO 2338 Ø5 h6 positioning pins in the mounting plate.